Organic Robotics Lab
Robotic fish powered by redox flow batteries are a promising path to longer, more efficient underwater missions. That's only possible with a reliable way to manage the liquid electrolyte fuel that powers them. I designed a refueling module to make that possible.
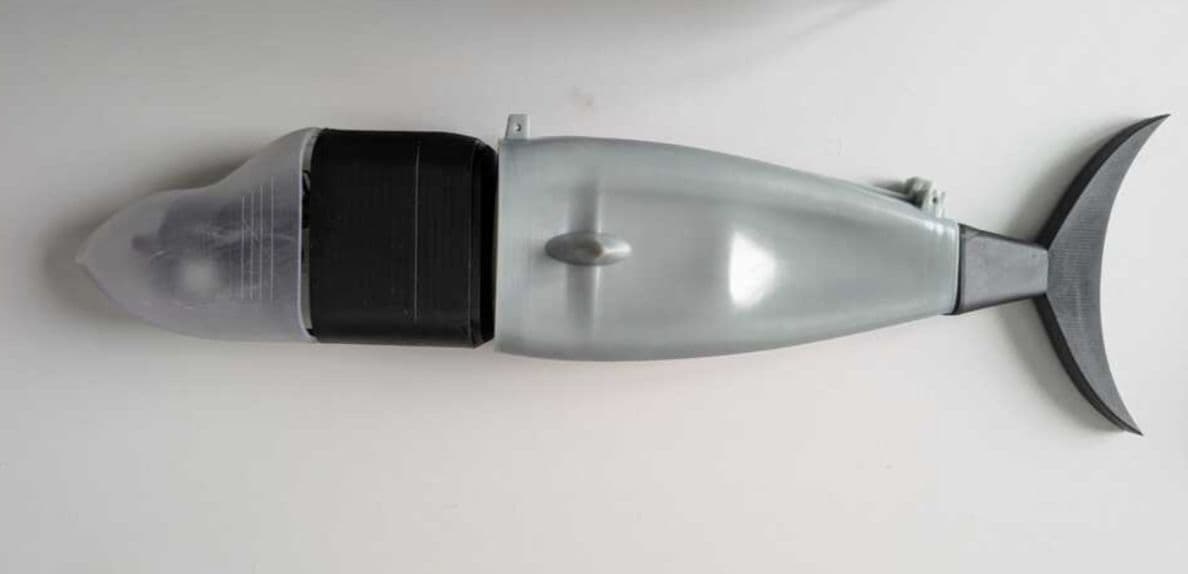
Sustainable underwater robots need a way to intake and discharge liquid electrolyte without hurting range or reliability.
Built around a single motor-driven pump controlled by an Arduino microcontroller for precise fuel transfer.
Made the module buoyant and modular, and fabricated it from lightweight, customizable 3D-printed parts.
The lab's funding ended before I had the chance to test the refueling module on the physical fish. The work above reflects where the design stood at that point.